Converting HART devices to Modbus systems is common in modern industrial upgrades. Many plants still use reliable field instruments installed years ago. Replacing every device can be expensive, disruptive, and unnecessary.
Hart To Modbus Communication usually requires a protocol gateway between the instrument and control system. HART commonly travels over a 4–20 mA loop with digital signals. Modbus RTU typically uses RS-485, while Modbus TCP operates through Ethernet. The gateway translates commands, measurements, status information, and diagnostic data between these different structures.
The real work begins with careful mapping. A pressure transmitter may report its process value in one register and alarms in another. Engineers must confirm register addresses, data types, byte order, scaling, baud rate, parity, and slave addresses. Small errors matter. A temperature reading of 25.0°C can appear as 250, 0.25, or an unreadable value when scaling is wrong.
Power and wiring also deserve attention. Check loop resistance, grounding, cable shielding, RS-485 termination, and available power before commissioning. Do not assume the gateway will correct every field problem. It will not.
Testing should include normal values, sensor faults, communication loss, and device restarts. Record the original HART variables before changing configurations. This creates a useful reference for troubleshooting and future maintenance. Some installations need extra engineering. That is normal. A practical conversion plan combines manufacturer documentation, controlled bench testing, and measured results from the operating plant. Measure twice. Deploy once.
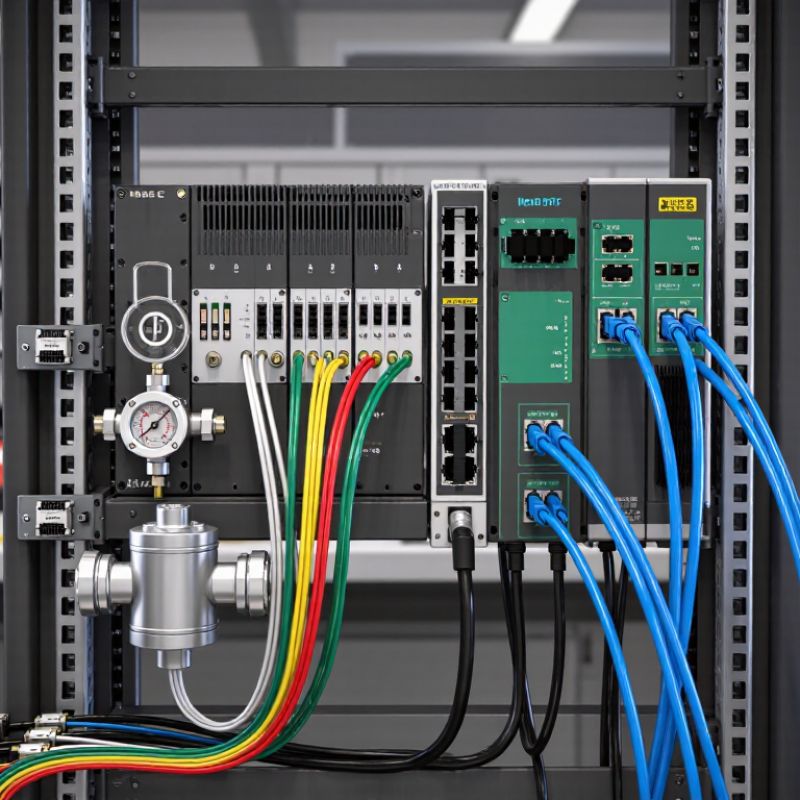
HART and Modbus solve different communication problems. HART adds digital data to a 4–20 mA signal. It can report process values, device status, configuration, and diagnostics. Modbus usually transfers data through registers over serial lines or Ethernet networks. The difference matters during conversion. A gateway cannot simply copy one signal into another. It must interpret HART commands and place the results into readable Modbus registers.
In practical commissioning, begin by listing each HART variable and its purpose. Map the primary process value to a holding or input register. Map units, alarms, and diagnostic information separately.
Define the Modbus slave address, baud rate, parity, and polling interval. For Ethernet systems, check the server address and register format. A temperature value may appear as a floating-point number, while a status flag may use a single bit. Small details cause large errors.
Test one device before expanding the network. Watch the current loop with a meter and compare it with the converted register value. Check byte order, scaling, and response timing. I have seen correct readings appear ten times too high because scaling was applied twice. Another imperfect assumption is treating every HART device identically. Device commands and available variables can differ. Keep the original engineering units visible, and document every register assignment near the control cabinet.
How to Convert HART to Modbus Communication?
Selecting the right HART-to-Modbus gateway starts with the field signal. HART overlays digital data on a 4–20 mA loop. The gateway must read variables, status, diagnostics, and device information without disturbing control signals. FieldComm Group reports more than 40 million HART-enabled devices installed worldwide, so mixed architectures remain common in operating plants.
A practical design places the gateway near the marshalling cabinet, with isolated channels and clear loop ownership. Choose Modbus RTU for short, simple serial networks. Choose Modbus TCP when the control network already uses managed Ethernet switches. Check polling speed carefully. A gateway reading thirty instruments may need several seconds, especially when devices return extended diagnostics. Fast is not always better.
Register mapping needs engineering discipline. Define scaling, byte order, alarm states, and failed-device values before commissioning. The Modbus Organization identifies registers and exception responses as core interoperability concerns, but real projects still suffer from inconsistent maps. I have seen a correct loop produce incorrect pressure because decimal placement was misunderstood. Small detail. Document every register.
Use galvanic isolation, shielded cabling, network segmentation, and role-based access. ISA/IEC 62443 guidance supports separating control assets from enterprise traffic. Do not treat the gateway as a simple protocol adapter. It becomes part of the automation system’s trust boundary. Field testing should compare handheld HART readings, gateway values, and Modbus registers under normal and fault conditions. The architecture may look clean on paper. Field wiring often disagrees.
How to Convert HART to Modbus Communication?
Reliable conversion begins with wiring, not software. HART normally rides on a two-wire 4–20 mA loop, using a 1200-baud digital signal. Install the gateway in parallel with the loop, not in series with the transmitter. Maintain correct polarity and verify the loop has about 250 ohms of effective load. Too little resistance can weaken communication. Too much resistance may reduce analog accuracy. Ground the cable shield at one point only. FieldComm Group’s 2023 technology overview reported more than 40 million HART-enabled devices in service, so legacy loop conditions deserve careful inspection.
Check voltage at the farthest device. Confirm the barrier supports digital overlay signals. Then configure the HART side with address, tag, engineering units, and primary-variable selection. Most point-to-point instruments use address 0. Multidrop operation requires unique addresses and a suitable loop design. The gateway should map each variable into Modbus registers, with documented scaling, byte order, status bits, and alarm handling. Modbus RTU settings commonly include 9600 or 19200 baud, 8 data bits, even parity, and one stop bit, but the gateway and PLC must match exactly.
Test one loop first. Compare the local display, measured current, and Modbus value. A 12 mA signal should represent the configured midpoint, not an assumed value. The Modbus application protocol specification defines register-based data exchange, but it does not define your instrument’s scaling. That part requires engineering judgment. I have seen conversions pass a bench test and fail after grounding changes. Document the exception. Recheck it onsite.
Reference values for wiring a two-wire HART current loop to a gateway and configuring its RS-485 Modbus RTU side. HART uses Bell 202 FSK at 1,200 bit/s, while the example Modbus RTU interface uses 9,600 baud, 8 data bits, even parity, and 1 stop bit.
Wiring note: Connect the HART loop to the gateway’s HART terminals with correct polarity and loop resistance. Connect the gateway’s Modbus A/B differential pair to the RS-485 network, maintain polarity, use a twisted pair, and apply termination only at the physical bus ends. HART and Modbus are different electrical and protocol layers, so a gateway is required for conversion.
Converting HART data to Modbus begins with a clear variable map. A gateway reads HART process data and places each value into a Modbus register. The primary variable usually represents the main measurement, such as pressure, temperature, or flow. Secondary, tertiary, and quaternary variables can follow separate register addresses. Do not assume identical mappings across devices.
A practical map should record the HART variable, Modbus address, data type, scale, unit, and status. For example, a pressure value may occupy two consecutive input registers as a 32-bit floating-point number. Another device may use a signed integer with a scale factor of 0.1. Check byte order carefully. Incorrect endianness can turn 25.6 into an impossible value. Small details matter.
Keep quality information visible. HART status can indicate an uncertain, saturated, or failed measurement. It should map to a dedicated Modbus status register or bit field. The gateway should also expose communication faults separately. During commissioning, compare displayed values with a calibrated field instrument. Record the raw register value before applying scaling. This makes troubleshooting faster. A first map is rarely perfect. Timing can also expose problems, especially when several devices share one polling cycle. Recheck update rates, address offsets, and units under normal operating conditions.
| HART Variable or Parameter | HART Source | Modbus Register Address | Modbus Data Format | Engineering Unit and Scaling | Access | Mapping Description |
|---|---|---|---|---|---|---|
| Process Variables | ||||||
| Primary Variable (PV) | HART Command 3, Primary Variable | 40001–40002 | IEEE 754, 32-bit floating point | Native engineering unit reported by the HART device; no additional scaling | Read-only | Maps the main measured process value, such as pressure, temperature, flow, or level, to two consecutive 16-bit Modbus registers. |
| Secondary Variable (SV) | HART Command 3, Secondary Variable | 40003–40004 | IEEE 754, 32-bit floating point | Native engineering unit reported by the HART device | Read-only | Maps the second dynamic variable supplied by the field device. Availability depends on the device configuration. |
| Tertiary Variable (TV) | HART Command 3, Tertiary Variable | 40005–40006 | IEEE 754, 32-bit floating point | Native engineering unit reported by the HART device | Read-only | Maps the third dynamic variable. The actual measurement depends on the device type and configured HART variable assignments. |
| Quaternary Variable (QV) | HART Command 3, Quaternary Variable | 40007–40008 | IEEE 754, 32-bit floating point | Native engineering unit reported by the HART device | Read-only | Maps the fourth dynamic variable when supported and enabled by the HART device. |
| Loop Current | HART Command 3, Primary Variable current | 40009 | Unsigned 16-bit integer | 0.001 mA per count; for example, 12,000 = 12.000 mA | Read-only | Stores the measured or reported analog loop current using a fixed three-decimal milliampere scale. |
| Percent of Range | HART Command 3, Percent of Range | 40010 | Signed 16-bit integer | 0.01% per count; for example, 5,000 = 50.00% | Read-only | Represents the primary variable position between the configured lower and upper range values. |
| Units, Status, and Device Information | ||||||
| PV Unit Code | HART Command 3 or variable-unit response | 40011 | Unsigned 16-bit integer | HART unit code; interpretation requires a unit-code lookup table | Read-only | Stores the unit identifier associated with the PV. The gateway should expose the decoded unit as a separate text or diagnostic value where required. |
| PV Status | HART response status and variable status | 40012 | Unsigned 16-bit bit field | Bit-coded status; 0 indicates no reported fault in this example | Read-only | Preserves communication, device, and measurement-quality information received from the HART response. |
| HART Communication Status | Gateway diagnostic result | 40013 | Unsigned 16-bit integer | 0 = healthy; 1 = timeout; 2 = invalid response; 3 = retry limit reached | Read-only | Indicates whether the gateway successfully obtained a valid response from the HART field device. |
| Polling Address | HART short address | 40014 | Unsigned 16-bit integer | 0–63 for traditional HART addressing | Read-only | Identifies the HART device address used by the gateway during polling. |
| Device Status Summary | HART standard status byte | 40015 | Unsigned 16-bit integer | Low byte contains the HART status byte; upper byte reserved | Read-only | Provides a compact diagnostic value for PLC, SCADA, or DCS logic. |
| Device Tag Reference | HART long tag or tag field | 41001–41008 | ASCII characters, two characters per register | Up to 16 ASCII characters in this example | Read-only | Maps the configured device tag into Modbus registers for identification and maintenance displays. |
| Configuration and Control Values | ||||||
| PV Lower Range Value | HART range configuration | 40016–40017 | IEEE 754, 32-bit floating point | Same engineering unit as the PV | Read-only or write-enabled | Defines the lower endpoint corresponding to the configured analog output range. |
| PV Upper Range Value | HART range configuration | 40018–40019 | IEEE 754, 32-bit floating point | Same engineering unit as the PV | Read-only or write-enabled | Defines the upper endpoint corresponding to the configured analog output range. |
| Damping Time | HART device configuration | 40020 | Unsigned 16-bit integer | 0.1 seconds per count; for example, 25 = 2.5 s | Read/write | Maps the configured damping value. Write operations should be validated by the gateway before being sent to the HART device. |
| Loop Current Mode | HART device configuration | 40021 | Unsigned 16-bit enumeration | 0 = analog enabled; 1 = fixed current; 2 = multidrop mode | Read/write | Represents the operating mode of the current loop. Enumeration values must match the gateway implementation. |
| Device Configuration Command | Gateway control register | 40022 | Unsigned 16-bit command code | 1 = refresh variables; 2 = write approved settings; 3 = clear command | Write-only | Provides an application-level trigger for HART read or write transactions. Access should be protected in the Modbus master. |
Converting HART to Modbus is rarely a simple wiring exercise. HART commonly carries 1,200-baud digital signals over analog loops, while Modbus uses structured registers and serial timing. A gateway must map variables, status codes, alarms, and engineering units without losing meaning. Record every tag before commissioning. Compare live values at the transmitter, gateway, and supervisory system. A 2024 industrial cybersecurity report found that 54% of large organizations considered supply-chain exposure a major resilience barrier. Treat the converter as part of that exposure, not as an isolated device.
Testing should include normal values, sensor faults, communication loss, and power recovery. Use a calibrated meter and a protocol analyzer. Check Modbus slave addresses, baud rate, parity, termination, and polling intervals. Duplicate addresses can create confusing, intermittent failures. They may appear only during heavy polling.
During troubleshooting, change one setting at a time and save timestamped logs. Field experience shows that rushed register mapping causes more faults than damaged hardware. I have seen correct values displayed with incorrect units, which is a quiet but serious failure.
Tips: Label each cable and register map. Keep a baseline capture from a healthy network. Review unused registers instead of assuming zero means safe. The World Economic Forum recommends stronger visibility across connected operational systems, so schedule monthly checks for errors, alarms, firmware status, and backup files. Test failover after maintenance, not only during installation. A gateway can pass data while still hiding diagnostic information. That deserves another review.
Start with the field signal and loop arrangement. The gateway must read digital data without disturbing the 4–20 mA control signal. Check channel count, isolation, diagnostics, and installation space. Field wiring may disagree with the drawing.
Choose Modbus RTU for short, simple serial networks. Choose Modbus TCP when managed Ethernet already serves the control system. Consider cable distance, switch design, maintenance skills, and polling load. Faster is not always better.
Installation near the marshalling cabinet often simplifies wiring and loop ownership. Use isolated channels where ground differences may appear. Label every cable beside its terminal. Small labels prevent large mistakes.
Record each variable, address, data type, scale, unit, and status. Primary, secondary, tertiary, and quaternary variables may use different addresses. Never assume two instruments share the same map. The first map may be wrong.
Compare raw registers with a calibrated field reading. Check whether values use floating-point or signed-integer formats. Confirm byte order before applying decimal scaling. A pressure reading of 25.6 can become nonsense.
Keep measurement status visible in a separate register or bit field. Distinguish uncertain, saturated, failed, and unavailable values. Report communication loss separately from a bad sensor. Zero does not always mean safe.
Test normal readings, sensor faults, communication loss, and power recovery. Compare transmitter values, gateway values, and supervisory values. Check addresses, baud rate, parity, termination, and polling intervals. Change one setting at a time.
Save timestamped logs and a healthy-network baseline. Review alarms, errors, firmware status, unused registers, and backup files monthly. Test recovery after maintenance, not only during installation. Some problems hide quietly.
Converting HART to Modbus communication requires a clear understanding of how the two protocols exchange data. HART supports digital communication over analog instrument wiring, while Modbus organizes information through registers that a control system can read and write. A successful conversion begins with selecting a suitable gateway and designing an architecture that matches the field devices, host controller, and network requirements. Proper wiring, power supply checks, device addressing, and communication parameters are also essential for stable operation.
The next step is mapping HART variables, such as process values, status information, and diagnostic data, to appropriate Modbus registers. Each data point should be documented with its address, format, scaling, and access type to avoid interpretation errors. After configuration, the network should be tested systematically by checking connectivity, validating measured values, reviewing diagnostic responses, and confirming update rates. Regular monitoring, accurate documentation, and timely troubleshooting help maintain reliable Hart To Modbus Communication over the long term.